| Characteristics | Description | |
|---|---|---|
| C1 | System under study | A 1/10‑scale autonomous vehicle built on a Traxxas teleoperated base (Traxxas Slash 4x4 Premium), retrofitted with an NVIDIA Jetson NX antenna, NVIDIA Jetson Orin Nano micro‑controller, onboard sensors including a Hokuyo UST‑10LX LiDAR and an Intel D435i depth camera, a Vedder Electronic Speed Controller, running the NVIDIA JetPack 5.0 SDK with ROS 2 middleware. |
| C2 | Physical acting components | No data available |
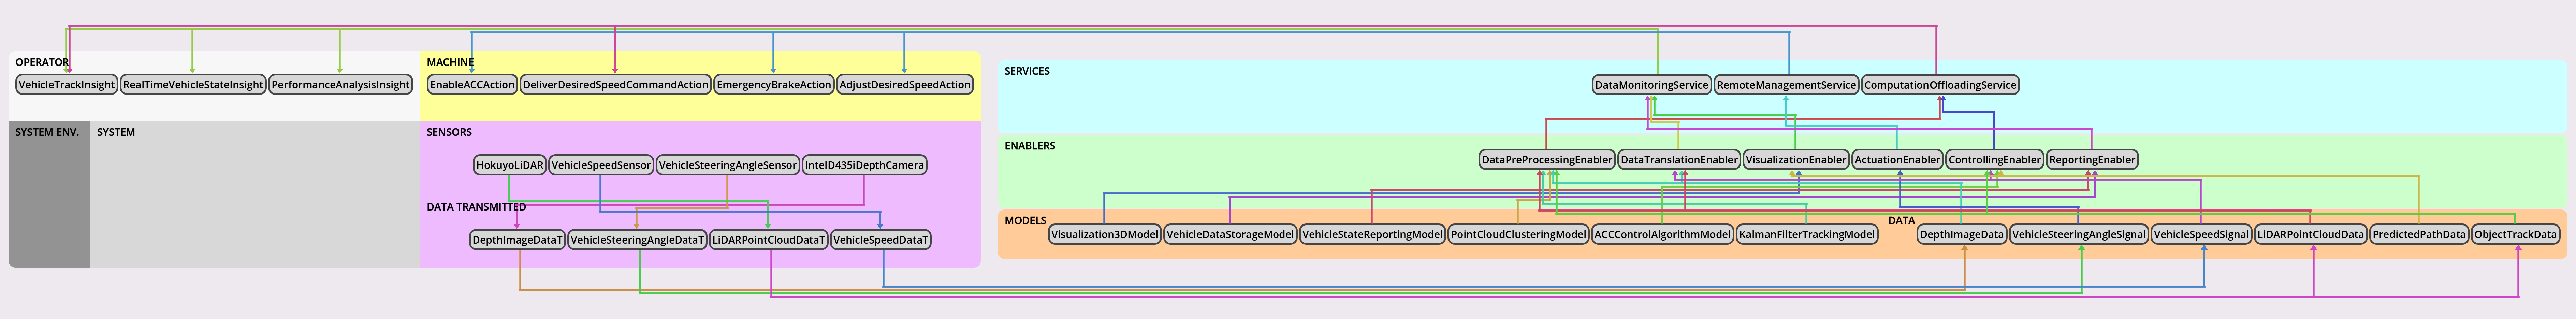
| C3 | Physical sensing components | HokuyoLiDAR: Hokuyo UST10LX LiDAR capturing raw point‑cloud data of surrounding vehicles. VehicleSpeedSensor: Provides real‑time vehicle speed data from the onboard speed sensor of the Traxxas Slash 4×4 Premium base. VehicleSteeringAngleSensor: Provides real‑time steering‑angle data from the steering servo of the vehicle. IntelD435iDepthCamera: Intel D435i depth camera providing depth images of the vehicle’s environment. |
| C4 | Physical-to-virtual interaction | DepthImageDataT VehicleSteeringAngleDataT LiDARPointCloudDataT VehicleSpeedDataT |
| C5 | Virtual-to-physical interaction | ACC outputs (desired speed, emergency braking commands) are serialised by the Data Translation FE, transmitted to PT, and handled by the Physical Twin Entity Actuation FE, which translates them into motor voltage commands for the speed controller and steering commands for the servo. Remote‐management UI commands (enable/disable ACC, set desired speed) follow the same routing path. |
| C6 | DT services | DataMonitoringService: Provides real‑time monitoring of vehicle state, includes 3D visualization and reporting to operators. RemoteManagementService: Allows operator to enable/disable ACC, adjust desired speed, and trigger emergency braking. ComputationOffloadingService: Offloads ACC algorithm computation, including lead‑vehicle detection and command delivery. |
| C7 | Twinning time-scale | No data available |
| C8 | Multiplicities | The DT consists of three distributed entities per ISO 23247: a single Physical Twin Entity on the vehicle, a single Digital Twin Entity on a cloud host, and a single User Entity on the operator workstation. Each entity hosts multiple Functional Entities (FEs)—Data Translation, Data Collection, Actuation, Visualization, Reporting, and Controlling—instantiated as separate ROS 2 packages. |
| C9 | Life-cycle stages | The DT operates in the Operated lifecycle stage, gathering real‑time operational data, executing ACC control, and providing monitoring and remote‑management services. It does not model the Design or Manufacturing stages of the vehicle. |
| C10 | DT models and data | Model: Visualization3DModel: Renders 3D visualization of vehicle state, surrounding object tracks, and predicted driving path. VehicleDataStorageModel: Persists vehicle state and object track data in a SQL database. VehicleStateReportingModel: Generates real‑time vehicle state reports and stores data in a SQL database. PointCloudClusteringModel: Performs DBSCAN clustering on raw point‑cloud data. ACCControlAlgorithmModel: Implements ACC control algorithm fulfilling ISO 15622 requirements. KalmanFilterTrackingModel: Applies Kalman‑filter tracking to clustered points to produce consistent object tracks. Data: DepthImageData: Depth image data received from the Intel D435i camera. VehicleSteeringAngleSignal: Vehicle steering‑angle signal after serialization and unit conversion. VehicleSpeedSignal: Vehicle speed signal after serialization and unit conversion. LiDARPointCloudData: Point‑cloud data received from the Hokuyo LiDAR. PredictedPathData: Predicted driving path generated by the ACC controller. ObjectTrackData: Clustered and filtered object track data derived from LiDAR point‑cloud. |
| C11 | Tooling and enablers | DataPreProcessingEnabler: Executes DBSCAN clustering and Kalman‑filter tracking on LiDAR point‑cloud data. DataTranslationEnabler: Serialises, units‑converts, and frames data between the PT and DT over ROS 2/UDP. VisualizationEnabler: Renders 3D visualization of vehicle, object tracks, and predicted path. ActuationEnabler: Converts desired speed and steering‑angle signals into motor voltage signals for the Vedder Electronic Speed Controller and steering servo. ControllingEnabler: Runs the ACC control algorithm and delivers desired speed commands. ReportingEnabler: Generates real‑time reports and stores vehicle data in a SQL database. |
| C12 | DT constellation | The constellation is organised as Physical Twin Entity (vehicle), Digital Twin Entity (cloud), and User Entity (3D visualization + control panel). Inter‑entity communication is realised over a Wi‑Fi network using ROS 2 topics transmitted via UDP, with the Data Translation FE orchestrating message framing, unit conversion, and timestamping. |
| C13 | Twinning process and DT evolution | The DT operates in the Operated lifecycle stage, gathering real‑time operational data, executing ACC control, and providing monitoring and remote‑management services. It does not model the Design or Manufacturing stages of the vehicle. |
| C14 | Fidelity and validity considerations | Real‑time data collection and 100 ms latency requirement ensure timely feedback; clock synchronization to 100 ms maintains data integrity; ACC algorithm follows ISO 15622 safety standards; data storage in a database and reporting provide traceability; however, no explicit V&V methodology is described beyond adherence to ISO requirements. |
| C15 | DT technical connection | PT and DT communicate over a Wi‑Fi link using ROS 2 topics carried over UDP. The Data Translation FE serialises and frames messages; Data Collection SE publishes vehicle state and object tracks with timestamps accurate to within 100 ms, conforming to the ISO 23247 Data Translation Format. |
| C16 | DT hosting/deployment | The Digital Twin Entity is deployed on a public cloud host; the Physical Twin Entity resides on the Jetson Orin Nano within the vehicle; the User Entity operates on an operator workstation or laptop, accessing the DT via the Data Translation and visualization components. |
| C17 | Insights and decision making | EnableACCAction: Enable or disable the ACC subsystem. DeliverDesiredSpeedCommandAction: Deliver desired speed command from ACC control algorithm to the vehicle. VehicleTrackInsight: Object tracks and predicted driving path for path planning. EmergencyBrakeAction: Trigger emergency braking of the vehicle. RealTimeVehicleStateInsight: Real‑time report of vehicle state and trajectory enabling anomaly detection. PerformanceAnalysisInsight: Analysis of ACC tracking accuracy and control performance informing sensor integration and tuning. AdjustDesiredSpeedAction: Set desired speed for the ACC subsystem. |
| C18 | Horizontal integration | No data available |
| C19 | Data ownership and privacy | No data available |
| C20 | Standardization | The architecture follows ISO 23247 (Digital Twin Manufacturing Framework) as the reference architecture, implements ISO 15622 for ACC control, and uses ROS 2 as open‑source middleware. OPC UA is referenced as a potential Data Translation method but not employed. |
| C21 | Security and safety considerations | Safety‑critical nature emphasized by latency requirement (≤100 ms) and clock synchronization (≤100 ms); compliance with ISO 15622 ensures ACC safety; the DT operates within a controlled Wi‑Fi network, but explicit cybersecurity measures are not detailed in the document. |